DTRACK meets ROS 2: open-source package from the KaliMoRo project
ifu releases dtrack_publisher for ROS 2 — from KaliMoRo for calibrating mobile robots with DTRACK. ART supported the IGF research project with tracking hardware.
Motion capture meets the Robot Operating System
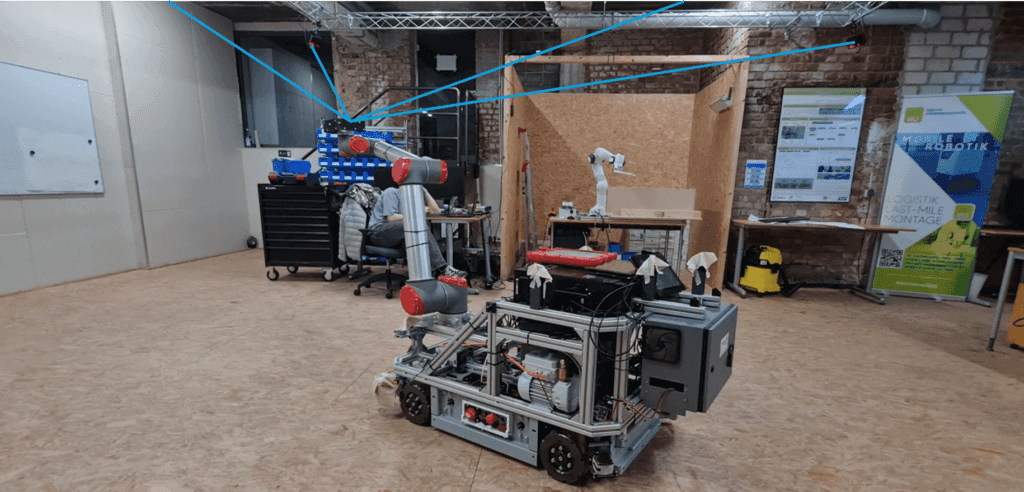
In the KaliMoRo research project (automatic calibration of mobile robots using large-scale metrology systems), the team at the Institute for Enterprise Cybernetics e.V. (ifu) at RWTH Aachen developed the ROS 2 package dtrack_publisher and published it on GitHub. ART is pleased to have supported the project with a DTRACK motion capture system — contributing to practical mobile-robot calibration.
What the repository offers
- DTRACK connection to ROS 2 — tracking data as ROS 2 topics
- Step-by-step guide for integration in mobile-robot calibration
- Openly accessible code as a starting point for your own development
The repository is available on GitHub: github.com/ifu-ev/dtrack_publisher. On the products page under Interfaces, see ROS 2 — dtrack_publisher (ifu) with a link to the repository.
Why this matters to us
KaliMoRo shows how industrial tracking technology and open research software can complement each other. Public results help smaller companies build on the same foundation. Related applications: Robotics & human-robot interaction. DTRACK basics: DTRACK4 features.
Thank you to Christoph Henke, David Schnermann, Dominik Birkel, and the entire project team for the collaboration.
Questions & contact
Package and ROS 2 integration: ifu.office@ifu.rwth-aachen.de
DTRACK motion capture system: Contact us or book an appointment.